Optimal use of force in Boston Dynamics’ robot dog
Optimal use of force in Boston Dynamics’ robot dog
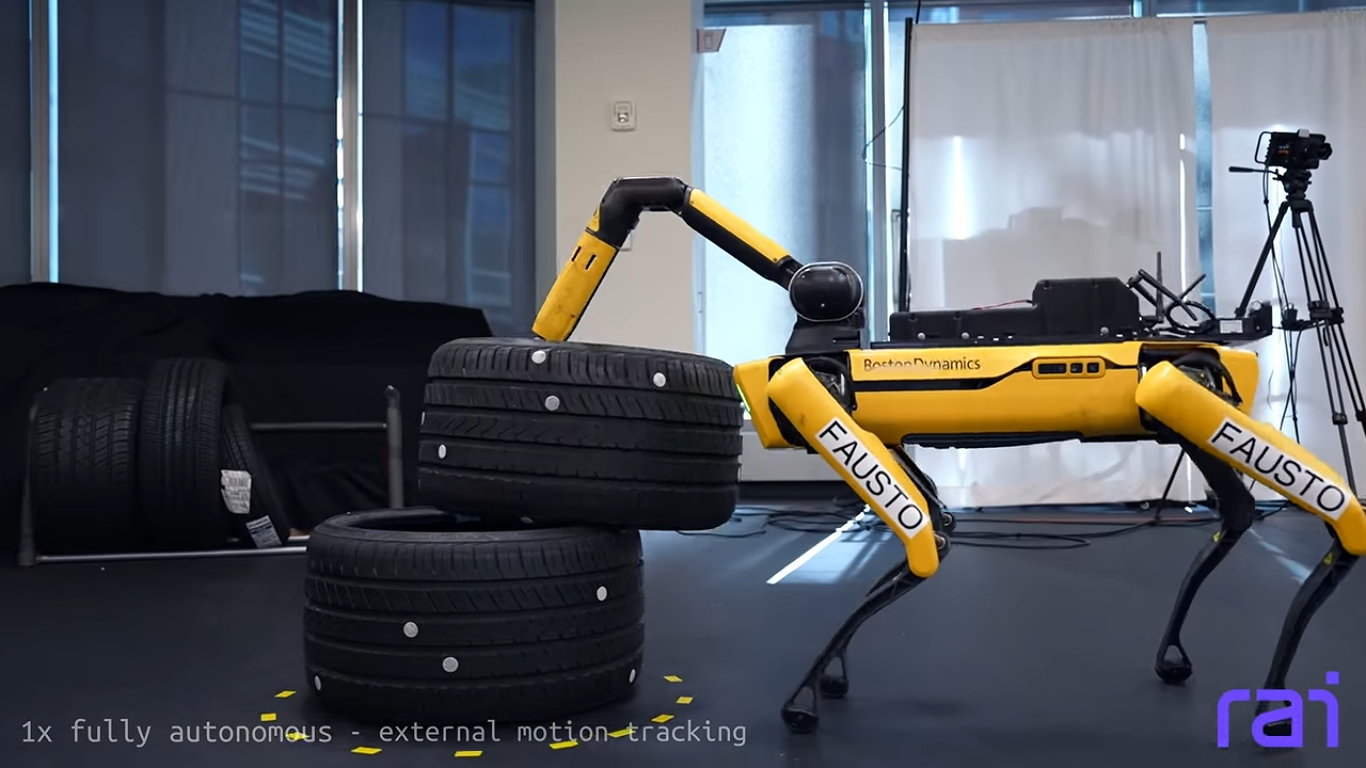
A four-legged robot is learning to perform a task that seems simple for humans but poses an enormous challenge for robotics: moving heavy objects without losing its balance, while also being able to react when something goes wrong. This is being demonstrated by researchers from the Ray Institute , who have unveiled a new showcase featuring Spot—the famous quadruped robot developed by Boston Dynamics.
The new version uses depth-sensing cameras installed on the robot itself to identify its surroundings and locate a tire. All the processing required to control its movements is handled by an onboard computer, allowing Spot to perform tasks in outdoor environments that were not specifically prepared for the experiment.